News Center
—— NEWS CENTER ——
Xi'an Shenghongchuang Instrument Co., Ltd.
Contact: Mr. Zhang
Mobile: 15529283736
Email: shc-sensor@qq.com
Address: Fortune Building, Sanqiao Street, Xixian New Area, Xi'an, Shaanxi Province
Frequent pressure fluctuations in hydraulic systems: first distinguish between “actual fluctuations” and “measurement fluctuations”
It is normal for pressure in hydraulic equipment to vary within a certain range during start-up and shutdown, directional changes, pressure holding, sudden load changes, or simultaneous operation of multiple actuators. However, if the pressure curve continues to oscillate, peak values repeatedly exceed limits, or actuators exhibit creeping, impact, or positioning deviations, both the hydraulic circuit and measurement chain should be investigated. Improper pressure sensor configuration can amplify pulsation, mechanical vibration, and electromagnetic interference into control signal fluctuations.
Common on-site issues include: an excessively large sensor range resulting in insufficient resolution in the low-pressure range, while an excessively small range can easily overload under pressure shocks; a pressure tap located close to the pump outlet, directional valve, or throttle orifice, causing the sensor to directly withstand high-frequency pressure pulses; and analog signal cables routed in parallel with power cables, introducing interference generated by equipment such as variable-frequency drives and solenoid valves.
Therefore, improving stability cannot rely solely on reducing controller gain. First, confirm whether the pressure signal is genuine, continuous, and repeatable. Then, configure sensor accuracy, output type, installation position, and filtering strategy according to the hydraulic system response speed, so that the controller receives reliable closed-loop feedback data.
Practical methods for identifying the source of fluctuations
Pressure measurement points can be arranged at the pump outlet, valve manifold inlet, and actuator inlet to compare pressure changes within the same operating cycle. If fluctuations are obvious at the pump outlet while the downstream end is relatively stable, the issue is often related to pump-source pulsation, relief valve dynamic characteristics, or accumulator condition. If fluctuations are greater at the downstream end, focus on checking valve spool vibration, pipeline resonance, load variations, and local throttling.
For equipment using PLCs, servo drives, or intelligent control instruments, it is recommended to record pressure, valve commands, pump speed, and actuator position simultaneously. When pressure fluctuations are synchronized with valve commands, they are usually related to control parameters or valve response. When pressure data jumps irregularly but mechanical movement remains unchanged, prioritize checking sensor power supply, grounding, and communication quality.
Original high-frequency data should be retained during diagnosis rather than observing only the average values displayed by instruments. For proportional valves or servo hydraulic systems with fast response, the sampling frequency should generally be no less than 10 times the primary fluctuation frequency of the measured pressure. If pressure pulsation is approximately 20 Hz, the sampling and recording frequency should preferably reach 200 Hz or above to avoid missing transient peaks.
Pressure sensor selection: range, accuracy, and dynamic response must be matched
A larger range is not necessarily safer for hydraulic pressure sensors. When the range is excessively oversized, the actual operating pressure occupies only a small portion of full scale, reducing the effective resolution of the analog signal. The controller may then misinterpret minor electrical noise as pressure changes. In general, the standard range can be selected at 1.25 to 1.5 times the system's normal maximum operating pressure, while confirming that the sensor's overload capability and burst pressure meet transient shock requirements.
For closed-loop pressure regulation, pressure holding, and synchronized control equipment, pressure transmitters with an accuracy of no less than 0.5%FS are recommended. For high-precision press-fitting, test benches, servo hydraulic control, and similar applications, products with 0.25%FS accuracy or higher may be selected. It should be noted that accuracy specifications should be evaluated together with full-temperature-range error, long-term stability, and repeatability, rather than considering only room-temperature calibration values.
Dynamic performance is equally critical. If the controlled object responds quickly but the sensor response time is too long, the feedback signal will lag, and the controller may continuously compensate and cause oscillation. For general hydraulic power unit monitoring, a response time of 10 ms to 20 ms can usually meet requirements. For conditions such as rapid directional switching and servo valve control, products with a response time of less than 5 ms are preferable, and the refresh cycle of the PLC analog input module should also be checked.
Selection of output signals and control system interfaces
In hydraulic applications with numerous motors, variable-frequency drives, and solenoid valves, 4 mA to 20 mA two-wire output should be given priority. Compared with 0 V to 10 V voltage signals, current signals are less sensitive to line voltage drop and common-mode interference, making them suitable for signal transmission over tens of meters or even longer distances. A normal zero-pressure signal corresponds to 4 mA, which also facilitates the control system's identification of faults such as cable breaks.
For multi-point pressure measurement, equipment retrofits, or applications requiring trend analysis, digital outputs such as RS485 Modbus can be selected. Digital communication can reduce analog conversion errors and provide access to extended information such as range, temperature, and fault status. However, bus topology, terminal resistors, communication addresses, and shield grounding must be standardized; otherwise, intermittent communication packet loss can also affect control stability.
If the control loop has extremely high real-time requirements, analog signals can be used as the primary closed-loop signal, while digital communication is used for parameter reading and equipment diagnostics. This configuration can balance millisecond-level control response with maintenance convenience, and it also facilitates comparison of data from different links during abnormalities to quickly identify the source of the problem.
Installation position determines feedback quality; pressure taps should avoid direct impact areas
Pressure sensors should be installed at locations that represent the controlled pressure, rather than simply where wiring is most convenient. Sensors used for hydraulic power unit protection can be installed on the main pump outlet manifold. Sensors used for actuator pressure control should be positioned as close as possible to the actual pressurized side of the cylinder chamber or hydraulic motor. Excessive distance between the control target and measurement location can cause feedback distortion due to pipeline damping and pressure transmission delay.
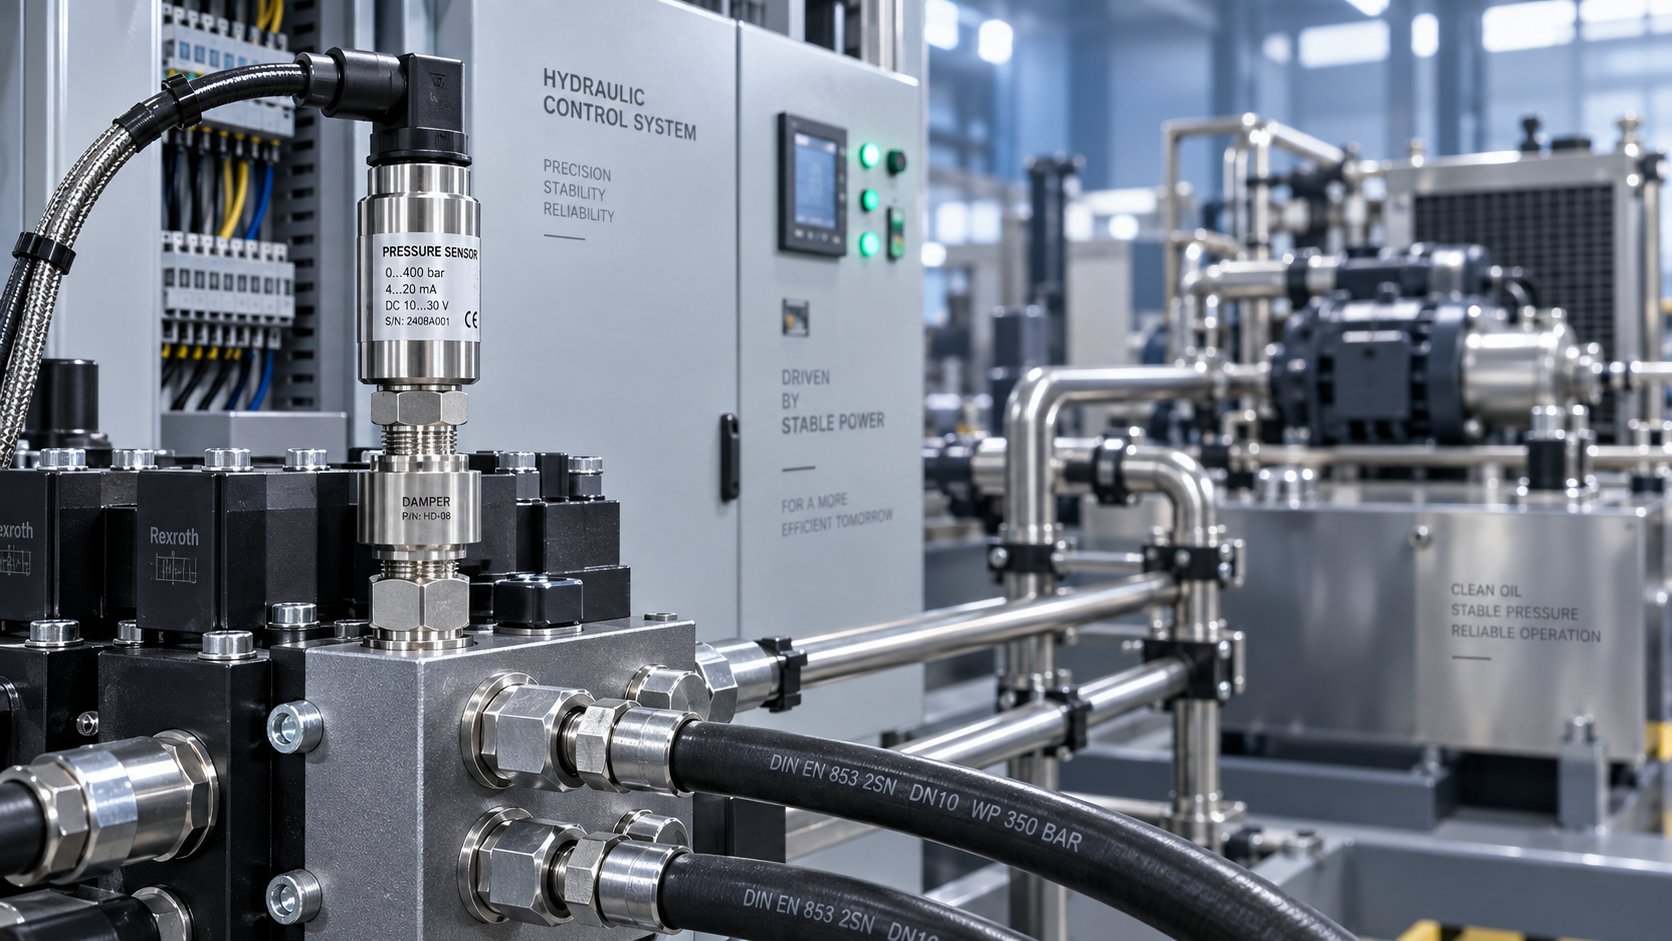
It is not recommended to install sensors directly at the outlet of a piston pump, at a rapid directional valve port, or in locations where severe hydraulic shock may occur. For unavoidable pulsating conditions, a damper, buffer fitting, or small-orifice throttling device can be added upstream of the pressure tap to moderately attenuate sharp pressure impacts. Damping components must not restrict flow excessively; otherwise, they will create obvious measurement delays and become detrimental to closed-loop regulation.
The sensor installation thread, sealing type, and wetted material must match the system pressure rating and oil type. Stainless-steel wetted constructions can be selected for common hydraulic oil applications. If corrosive media, special emulsions, or higher oil temperatures are present, seal material and media compatibility should be further confirmed. The pressure tap should also be cleaned before installation to prevent metal chips and sealing residues from blocking the pressure passage.
Layout details for reducing vibration and pulsation effects
When vibration from the pump assembly or valve block is significant, a short impulse line can be used to install the sensor on a relatively stable bracket. However, the impulse line length should be properly controlled to prevent excessive length from introducing additional lag. For high-frequency dynamic control, direct installation combined with mechanical vibration isolation should generally be prioritized to ensure a short and rigid pressure transmission path.
If the system has periodic pressure pulsation, a buffer structure with an appropriate volume can be selected according to the pulsation frequency. Taking pump-source pulsation as an example, relying solely on software filtering can improve display smoothness but cannot reduce actual pressure peaks. Only the proper configuration of accumulators, damping components, and pressure sensor locations can simultaneously improve both the hydraulic circuit and measurement signal.
After on-site commissioning, verification should be performed separately under no-load conditions, rated load, and maximum operating frequency. It is recommended to record at least 30 consecutive operating cycles and observe the maximum pressure, minimum pressure, peak-to-peak value, and settling time. If the peak-to-peak value under the same operating condition exceeds 5% of the set pressure, the pressure tap location, valve parameters, and filter time constant should be rechecked.
Coordinate signal processing and control parameters to avoid “over-filtering”
After the pressure signal enters the PLC or control instrument, strategies such as limiting, moving averaging, low-pass filtering, and outlier rejection can be configured. Their purpose is not to conceal actual hydraulic system faults, but to suppress high-frequency noise that is meaningless for control. The filter time constant should be shorter than the primary response time of the controlled process to avoid feedback delay and regulation lag.
For example, if a pressure-holding circuit has a pressure build-up time of 500 ms, the filter time constant can initially be adjusted within a range of 20 ms to 50 ms. If it is set to 300 ms or above, the pressure signal will be more stable, but proportional valve adjustment will lag noticeably, and the system may exhibit periodic fluctuations that are “low first, then high.” Different equipment should be confirmed based on actual pressure curves rather than using fixed parameters indiscriminately.
Controller PID parameters should be tuned after ensuring that the sensor signal is stable and installation is correct. Typically, first reduce the proportional gain and gradually increase it until the system is just about to exhibit slight oscillation, then add an appropriate amount of integral action according to the steady-state error. The derivative term should be used cautiously because it is sensitive to measurement noise. Stable pressure sensor output is the basis for obtaining reasonable PID parameters.
Power supply, wiring, and maintenance are equally important
Pressure sensors should preferably use a stable 24 VDC industrial power supply and be properly routed separately from loads such as high-power solenoid valves and contactors. Sensor signal cables should use shielded twisted-pair cables and should avoid long-distance parallel routing with power cables whenever possible. Where avoidance is impossible, a spacing of more than 300 mm should be maintained, and cables should cross each other at right angles.
The shielding layer is generally grounded at one end, preferably near the control cabinet, to reduce ground-loop interference. The treatment of sensor housing grounding, control cabinet protective grounding, and the analog signal common terminal should comply with equipment electrical design specifications. When grounding methods are disorganized, even high-accuracy pressure transmitters may experience zero drift and random signal jumps.
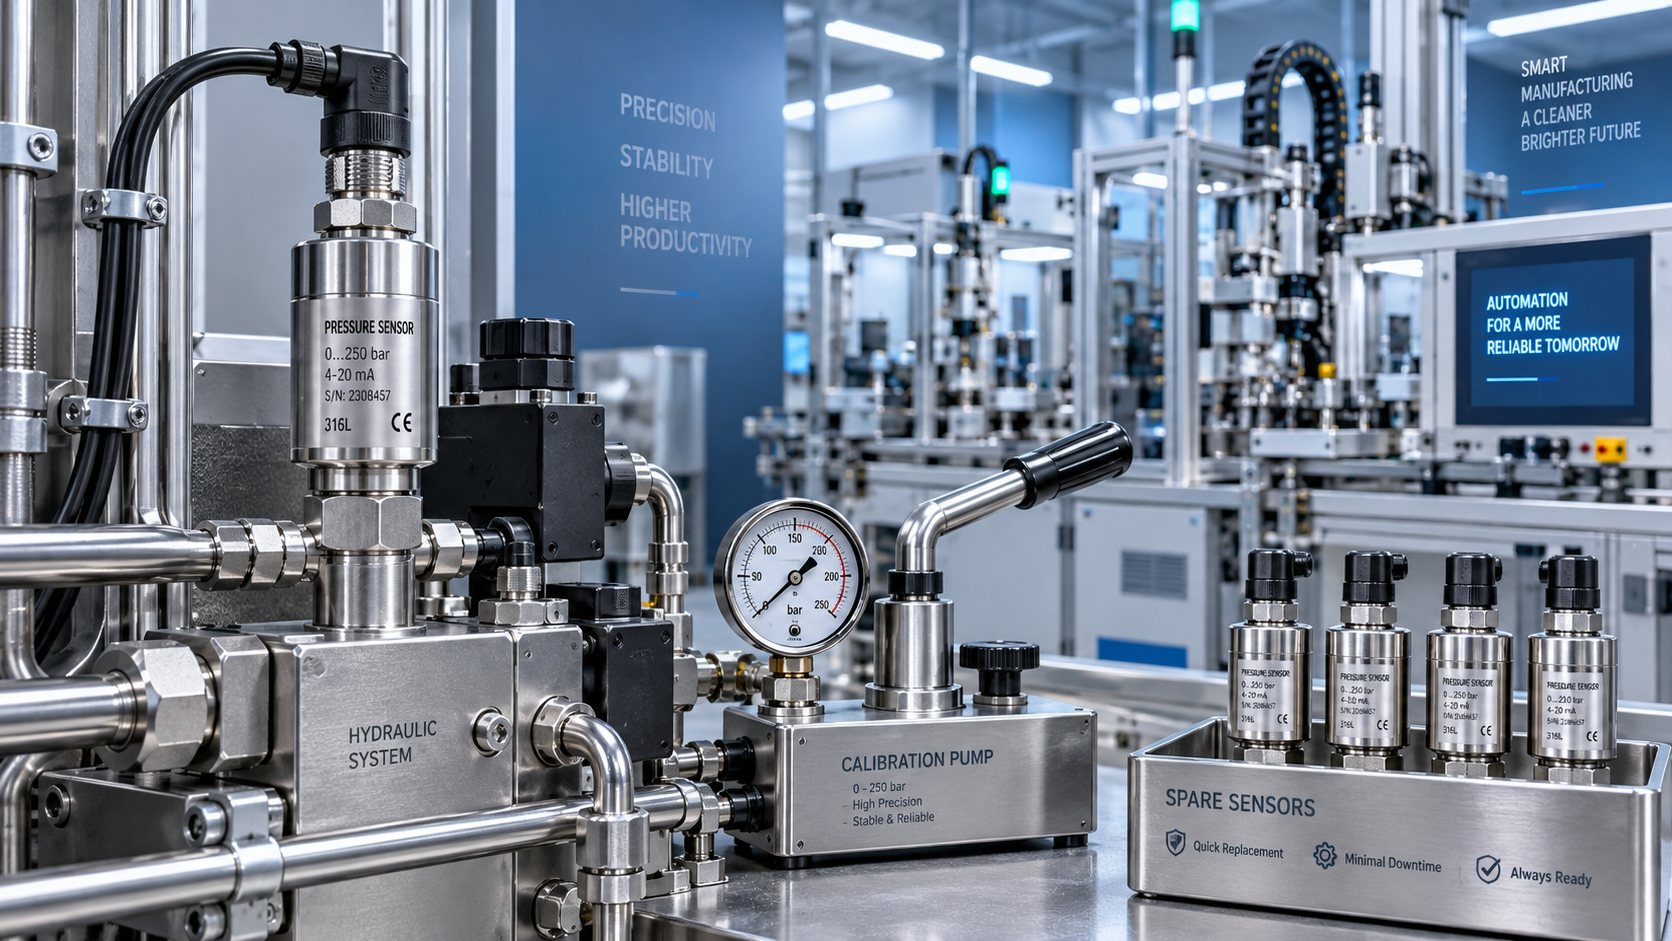
It is recommended to include pressure sensors in a preventive maintenance plan: inspect fitting leakage, cable wear, and fastening condition every 6 months; verify zero point and full scale every 12 months according to equipment accuracy requirements; and promptly retest after overpressure shock, severe oil contamination, or abnormal pressure curves occur. Xi'an Shenghongchuang Instrumentation Co., Ltd. can provide pressure sensor selection and supporting measurement and control solutions based on hydraulic system pressure range, media temperature, installation interface, output signal, and control cycle, helping equipment achieve more stable pressure feedback and operational control.
Related Recommendations
 How does a pressure sensor convert changes in applied force into usable electrical signals?
 Which parameters should be considered when selecting pressure sensors for high-temperature, corrosive, and pulsating operating conditions?
 Hydraulic equipment pressure fluctuates frequently. How can sensors be configured to improve control stability?
 When purchasing pressure sensors, how can you evaluate service life and total maintenance costs beyond the unit price?